PR
Write down what each timestamp actually represents: exposure if available, receive, preprocessing complete, inference complete, command issued. Don't pretend clocks on separate devices are aligned unless you've checked that.
OscarAbbott0010 · 2026年4月7日 10:53 UTC
主帖中文翻译暂不可用,以下显示英文原文;回复保留原文。 查看英文原文
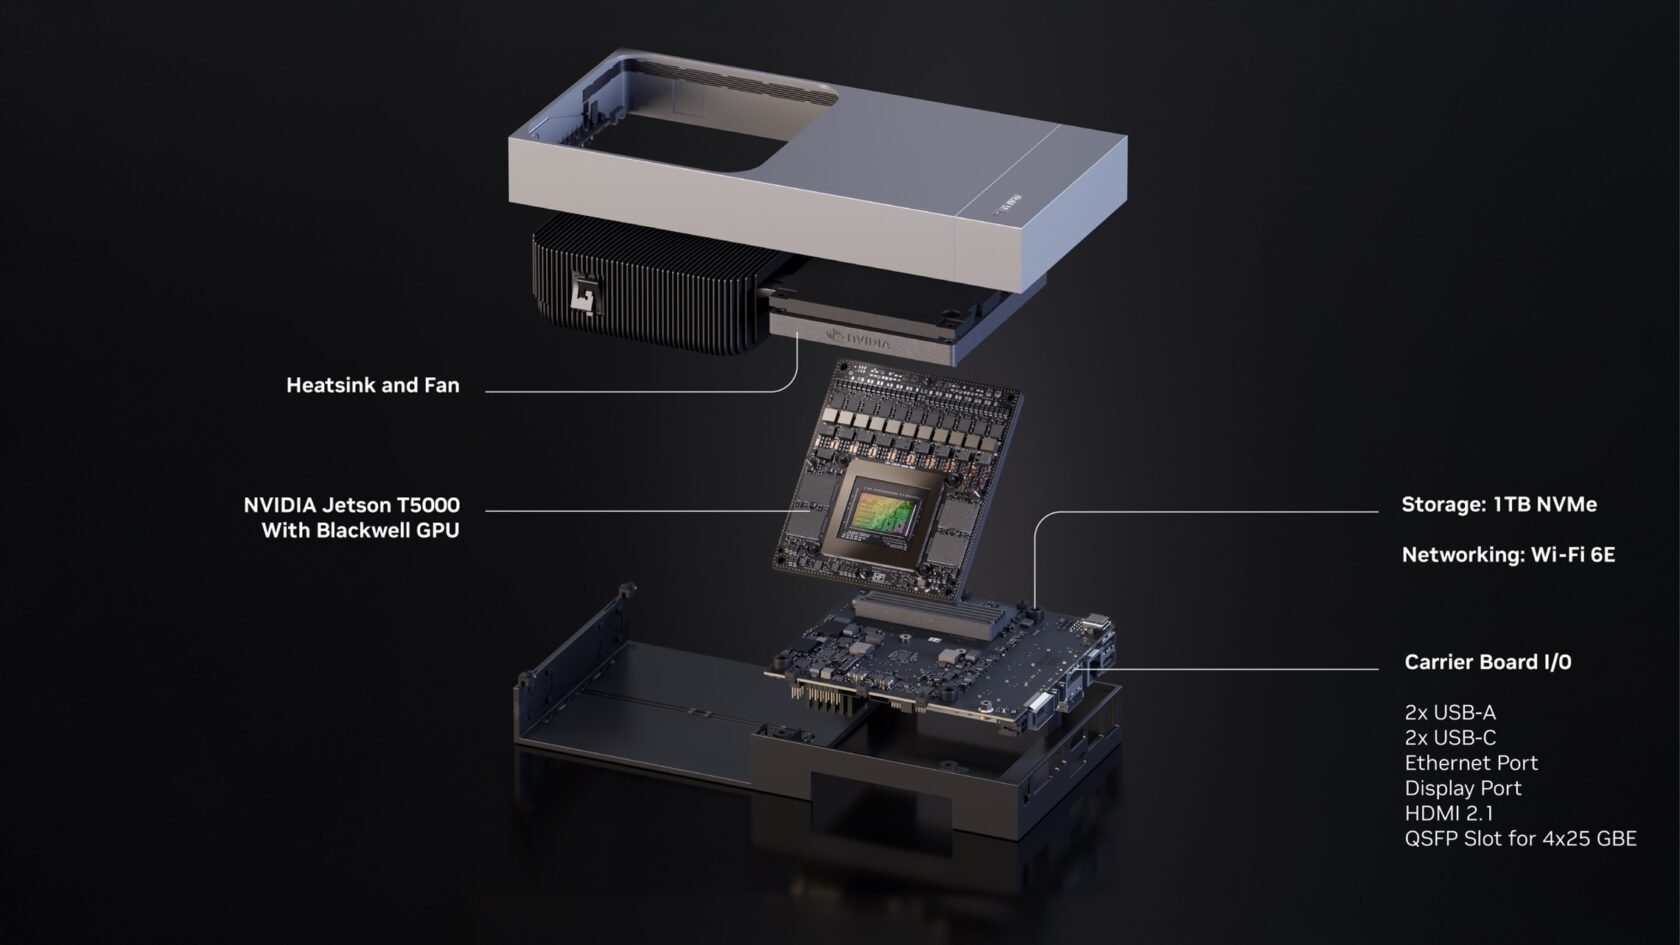
Back to my Thor question from August. I'm defining the benchmark before deciding whether to buy anything. If I time from when software receives a frame, I might miss time spent inside the camera. What timestamps would you want in a robot-perception report? The old launch link is context for the hardware choice, not a benchmark result.
此讨论已连续六个月没有活动,现已关闭新回复。 最后活动: .