简体中文界面。帖子、指南及政策正文保留原文;未对原文作自动翻译。

FR5 vacuum tooling: move the generator off the wrist?

PriyaIO · 2026年3月16日 16:54 UTC

回复讨论
PR
PriyaIO
Looking at an FQE arrangement for a small handling trial. The manual distinguishes external-vacuum M versions from the Xb/Xc ejector versions. I'm weighing up less hardware on the wrist against the hose route and response I then have to account for. Anyone else start with an off-robot supply in mind and change direction once they drew the cell? https://pimmedia.schmalz.com/MAM_Library/Dokumente/Bedienungsanleitung/PGE/4682cec81141_BAL_PGE-05822_en-EN_001.pdf
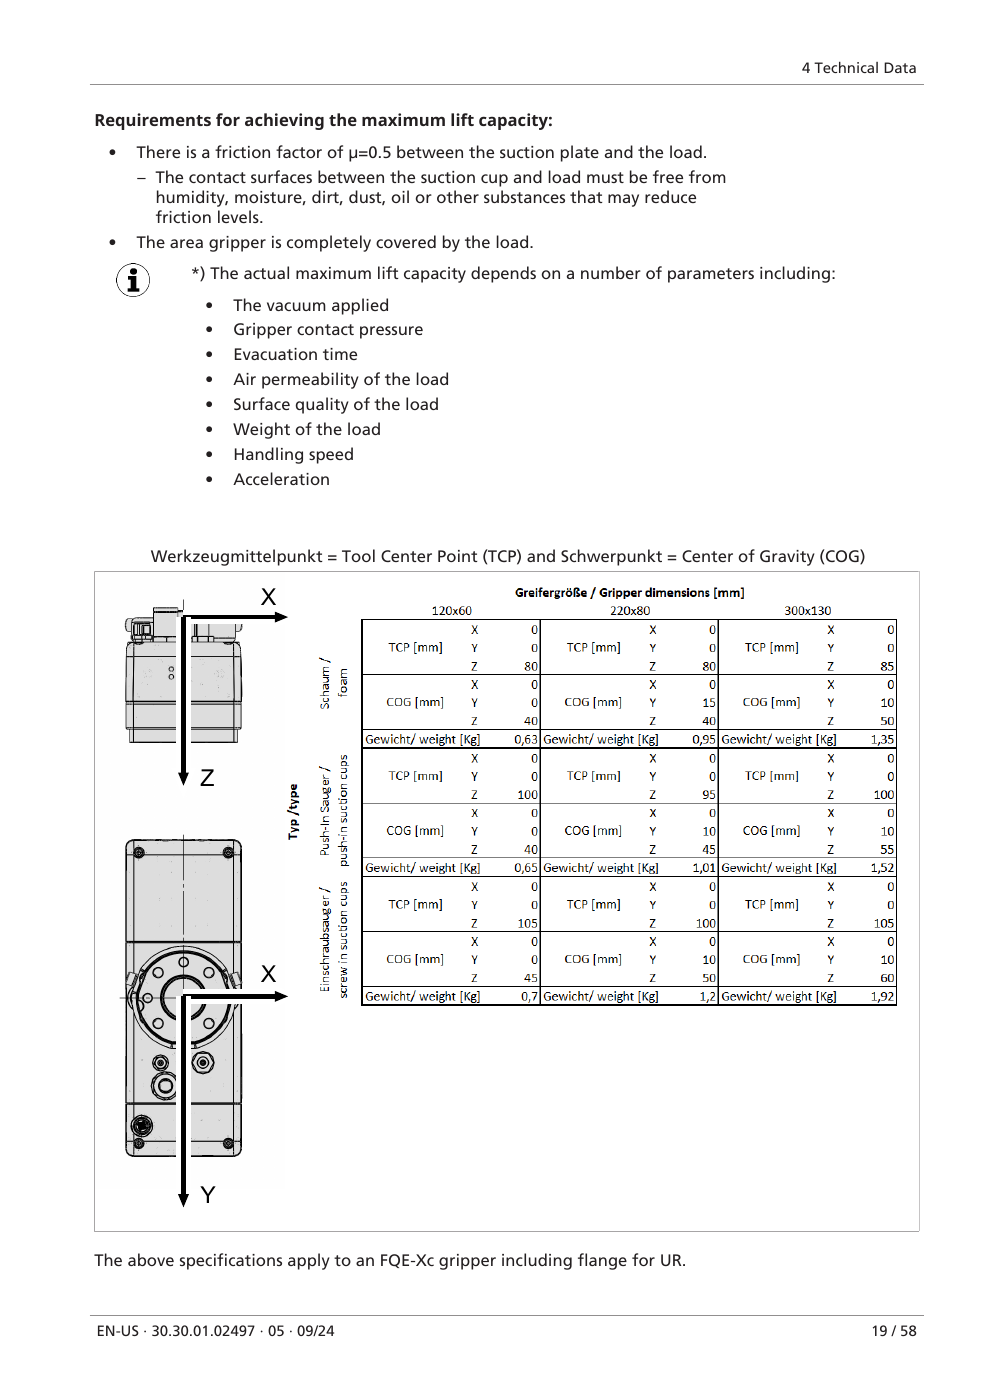
Page 19 of Schmalz's September 2024 FQE manual, with tool weights, centre-of-gravity diagrams and the UR-flange qualification
Schmalz FQE operating instructions: weights and centre of gravity

FQE-Xc table includes a UR flange. These are not confirmed weights or compatibility claims for a Fairino-mounted assembly.

Manual extract: Schmalz, revision 05, September 2024, page 19 · · Source record

4 条回复

TO
TomMill
回复 PriyaIO

The hose gets a route on my drawing, not a note saying 'hose to suit'. Otherwise it turns up at the end and goes wherever there's room.

0
CA
CarlaAbbott0053
回复 PriyaIO

I'd mock up the whole travel with a hose before committing to the bracket. A tidy home position can hide an awkward bend at the far end.

0
PR
PriyaIO
回复 PriyaIO

Yes. I also want grip confirmation and timeout behaviour defined at the tool, not an assumption that switching the supply on means a box is attached.

0
BE
BenBench
回复 PriyaIO

ah, so moving the pump isn't a free payload upgrade. You're moving a design problem as well.

0

参与讨论

欢迎来到 Application Robot

所有人都可以阅读论坛。登录或注册后即可发起讨论、回复或上传照片。

忘记密码?

注册账号即表示你同意我们的 使用条款 社区准则。请阅读我们的 隐私政策 ,了解我们如何处理你的信息。