Cell integration
Measure Robot Cycle Time Without Hiding Waits and Failures
Measure robot and cell cycle time with explicit event boundaries, trustworthy timestamps, representative trials, and comparisons that retain waits and failures.
Published specifications & owner discussion
| Nominal payload | 16 kg |
|---|---|
| Reach | 1,034 mm |
| Pose repeatability | ±0.03 mm |
| Axes | 6 |
Source checked . Manufacturer specifications.
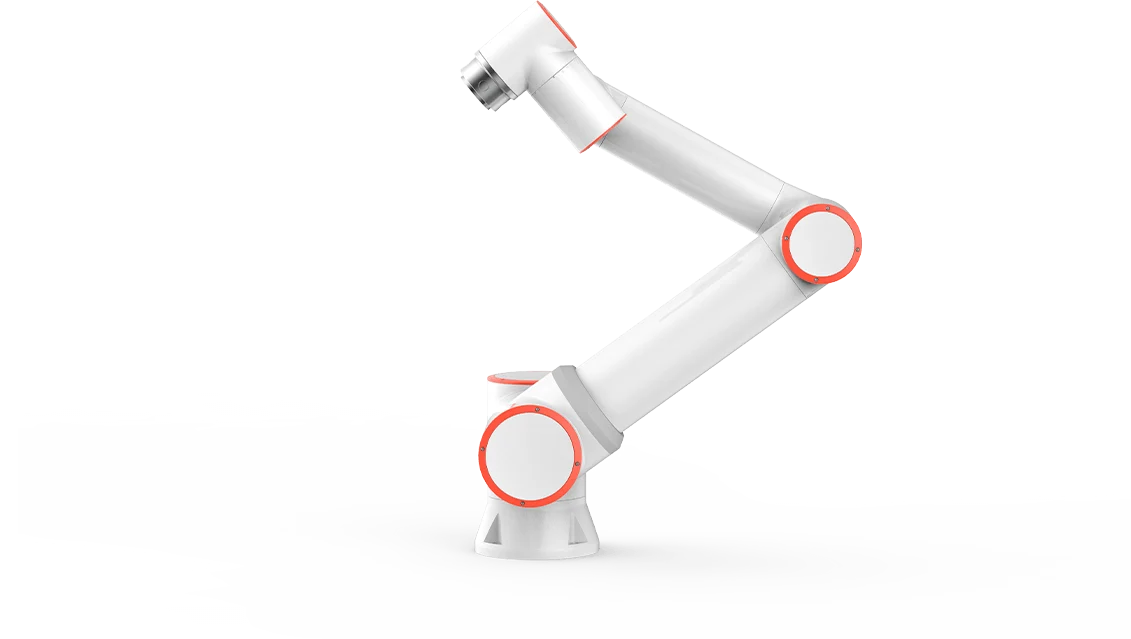
Product image:Fairino.
Choose for the load and layout together: FR16 has more nominal payload than FR10 but less reach. A heavier arm is not automatically a better fit.
Ask the supplier to demonstrate your complete application with representative parts and tooling. Confirm the exact configuration, controller, interfaces, local support, and delivery scope.
This profile records published information. Community reviews should describe the installation, time in use, and observed results.
Read community discussionsMeasure robot and cell cycle time with explicit event boundaries, trustworthy timestamps, representative trials, and comparisons that retain waits and failures.
Account for the gripper, adapters, services and workpiece, calculate a hypothetical combined centre of gravity, and prepare load records for qualified integration.
Scope CNC tending from blank presentation to accepted finished parts, including workholding, chips, machine handshakes, recovery and useful unattended time.