Robot learning
Budget a Robot Learning Setup Beyond the Arm and GPU
Build a robot learning budget around complete experiments: hardware, cameras, compute, storage, integration, operator time, and evidence-based purchase gates.
Published specifications & owner discussion
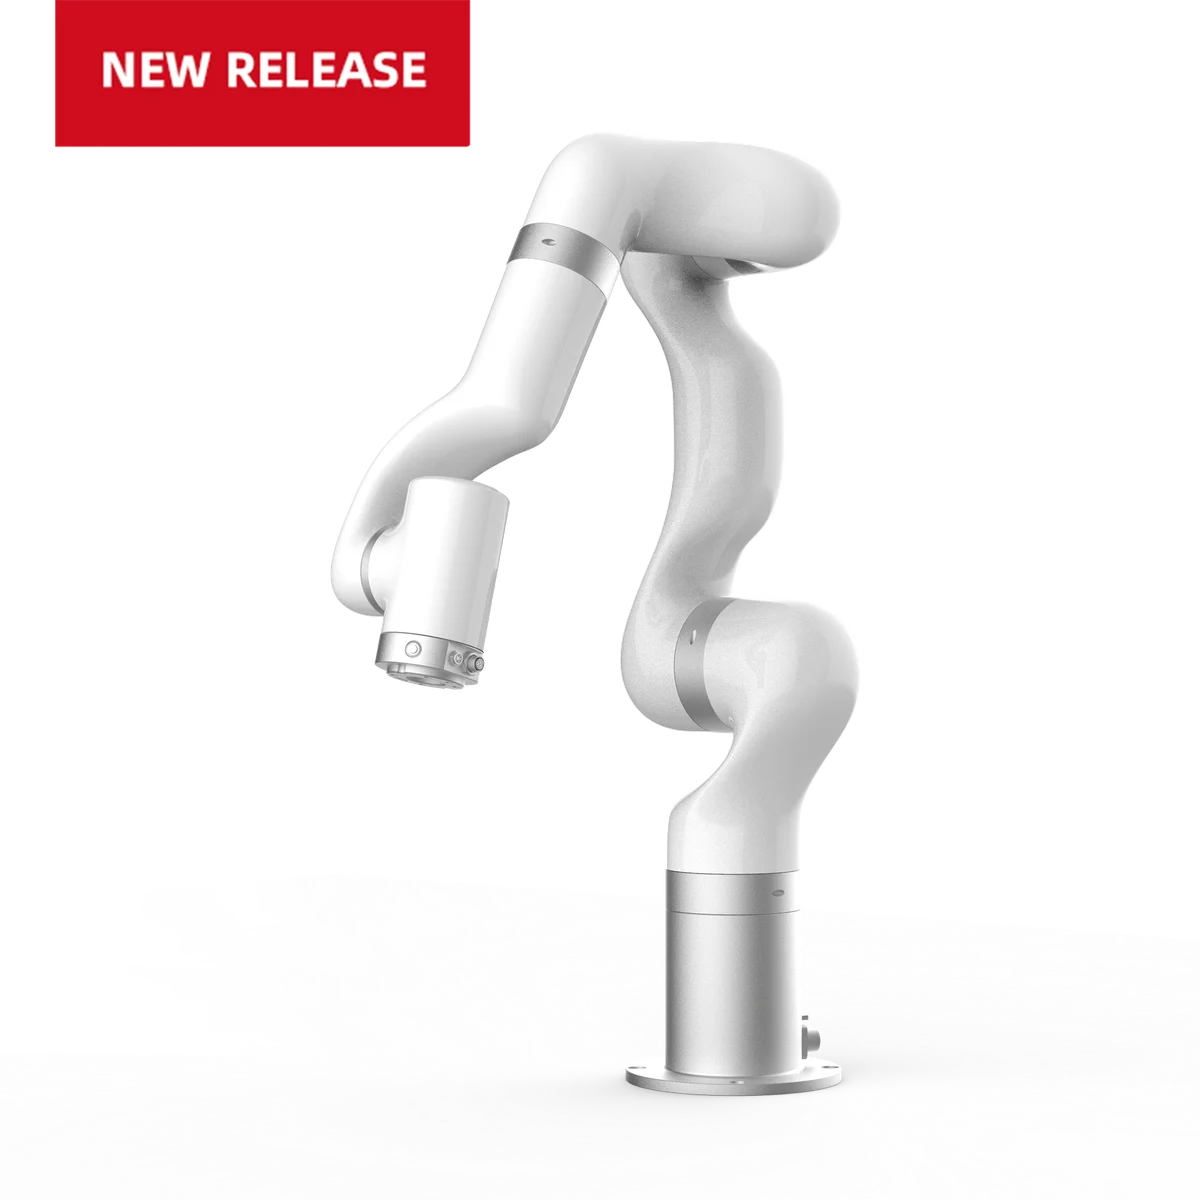
| Nominal payload | 5 kg |
|---|---|
| Reach | 850 mm |
| Pose repeatability | ±0.02 mm |
| Axes | 6 |
Source checked . Manufacturer specifications.
Product image:UFACTORY.
Evaluate the complete experiment: arm, control interface, sensing, tooling and the engineering time needed to make them work together.
Ask the supplier to demonstrate your complete application with representative parts and tooling. Confirm the exact configuration, controller, interfaces, local support, and delivery scope.
This profile records published information. Community reviews should describe the installation, time in use, and observed results.
Read community discussionsBuild a robot learning budget around complete experiments: hardware, cameras, compute, storage, integration, operator time, and evidence-based purchase gates.
Choose and preserve camera views that reveal grasping, transfer and release, then verify the observations a LeRobot policy actually receives.
Choose a robot programming workflow by separating taught poses, motion logic and external software, then plan the checks needed to move from simulation to a real cell.