Programming & controls
Specify Robot I/O Handshakes, Faults, and Restart Behavior
Build a robot I/O contract that covers electrical compatibility, signal ownership, request acknowledgements, faults, and restart behavior before commissioning.
Published specifications & owner discussion
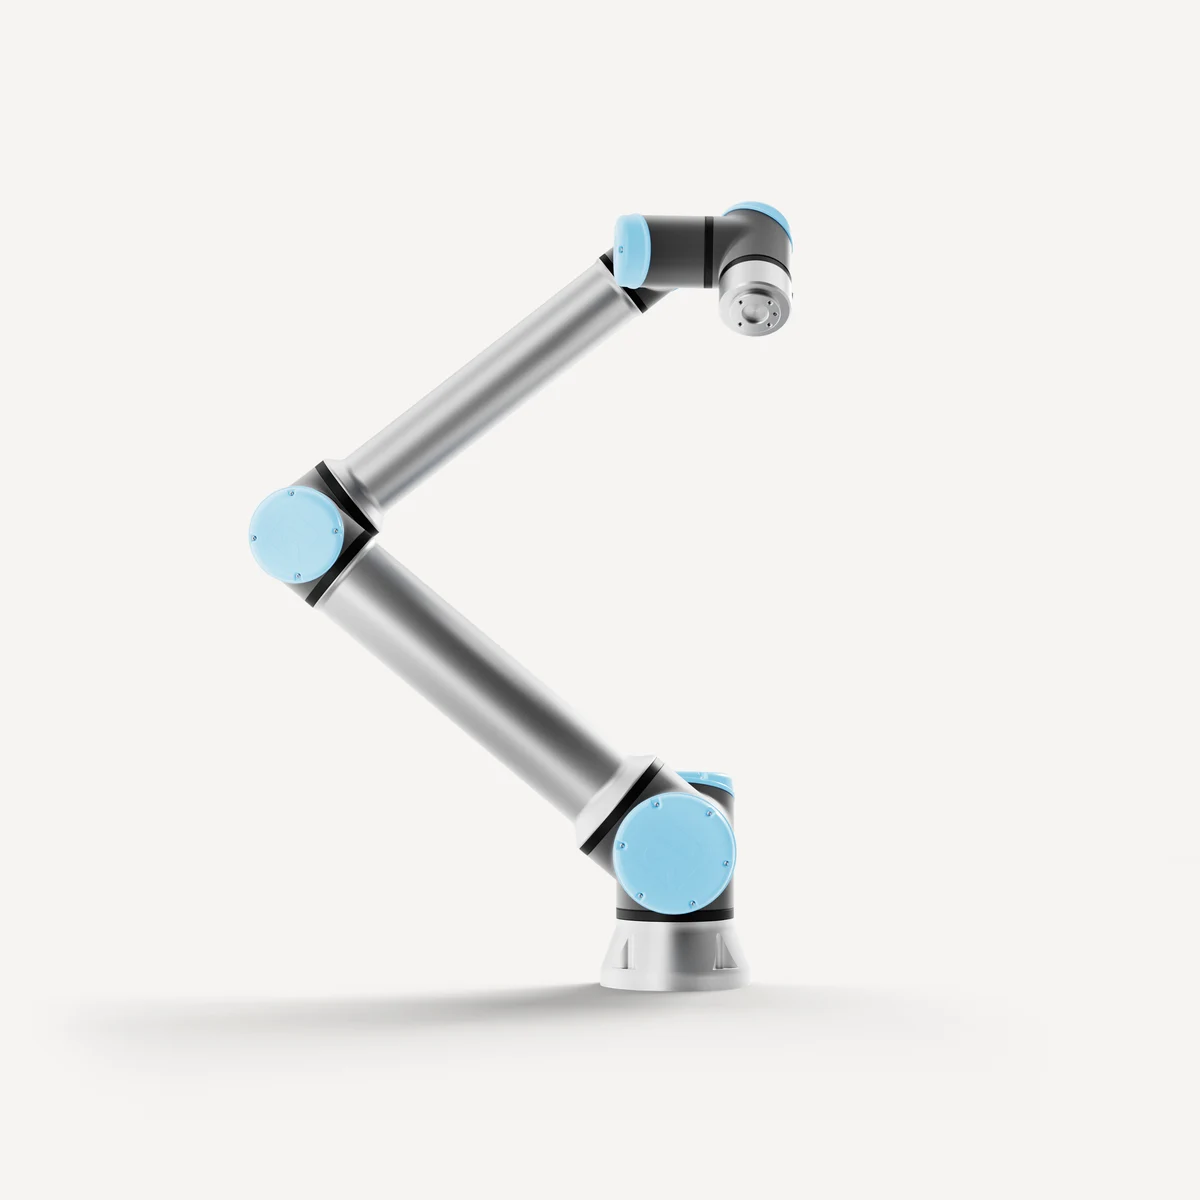
| Nominal payload | 12.5 kg |
|---|---|
| Reach | 1,300 mm |
| Pose repeatability | ±0.05 mm |
| Axes | 6 |
Source checked . Manufacturer specifications.
Product image:Universal Robots.
An option to compare with FR10 where a larger tool or a longer transfer is involved. Match the quoted configuration before comparing package prices.
Ask the supplier to demonstrate your complete application with representative parts and tooling. Confirm the exact configuration, controller, interfaces, local support, and delivery scope.
This profile records published information. Community reviews should describe the installation, time in use, and observed results.
Read community discussionsBuild a robot I/O contract that covers electrical compatibility, signal ownership, request acknowledgements, faults, and restart behavior before commissioning.
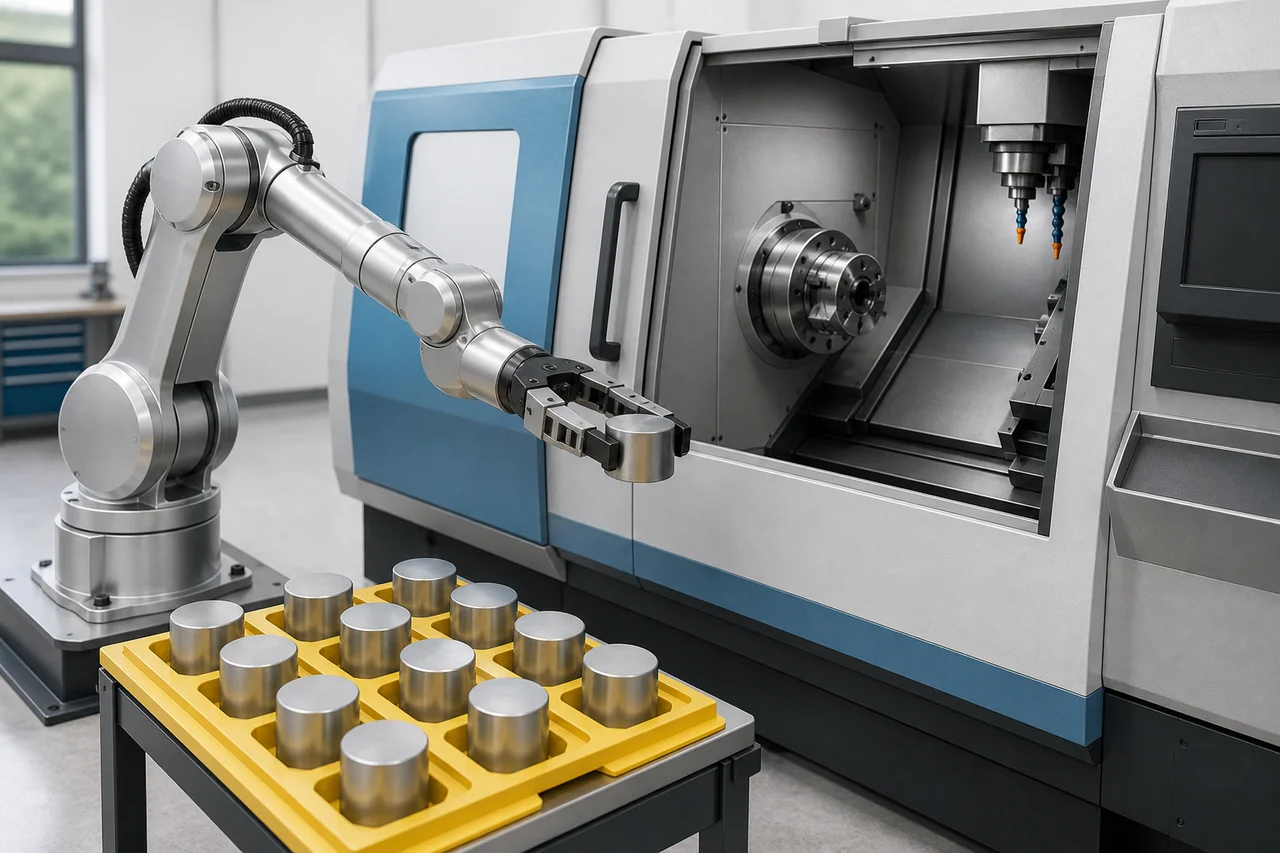
Scope CNC tending from blank presentation to accepted finished parts, including workholding, chips, machine handshakes, recovery and useful unattended time.
Build a five-year ownership model that separates installed cost, recurring operation, repairs, downtime and end-of-life work using traceable inputs and scenarios.