机器人学习
Budget a Robot Learning Setup Beyond the Arm and GPU
Build a robot learning budget around complete experiments: hardware, cameras, compute, storage, integration, operator time, and evidence-based purchase gates.
简体中文界面。帖子、指南及政策正文保留原文;未对原文作自动翻译。
LeRobot 项目、示教、数据集及切合实际的硬件选择。
Build a robot learning budget around complete experiments: hardware, cameras, compute, storage, integration, operator time, and evidence-based purchase gates.
An August 2026 launch snapshot of Jetson Orin Nano 2: announced hardware, unanswered pricing questions, and a practical evaluation plan for robot-side vision and learning.
Evaluate a LeRobot diffusion policy against a fair baseline, measuring task outcomes, sampling variation, action timing and checkpoint reproducibility.
Audit robot demonstrations for observable actions, timing, task consistency, episode boundaries, and evaluation leakage before spending time on policy training.
Understand ACT prediction chunks, action execution and temporal ensembling, then evaluate correction behaviour under a pinned LeRobot implementation.
Choose a tractable LeRobot task, freeze your setup, plan demonstrations and evaluation, and define evidence that earns the next stage of a learning project.
Prepare a reproducible LeRobot training run, verify its configuration and checkpoints, and judge the resulting policy with independent task outcomes.
Use the LeRobot visualizer to inspect episode boundaries, camera streams and actions, and distinguish dataset defects from loading or display failures.
Plan and verify SO-101 leader and follower calibration with LeRobot, preserving arm identity, joint meaning and evidence for consistent demonstrations.
Choose and preserve camera views that reveal grasping, transfer and release, then verify the observations a LeRobot policy actually receives.
Install a documented LeRobot release, select the right dependencies, and verify imports, video decoding and configuration before connecting a robot.
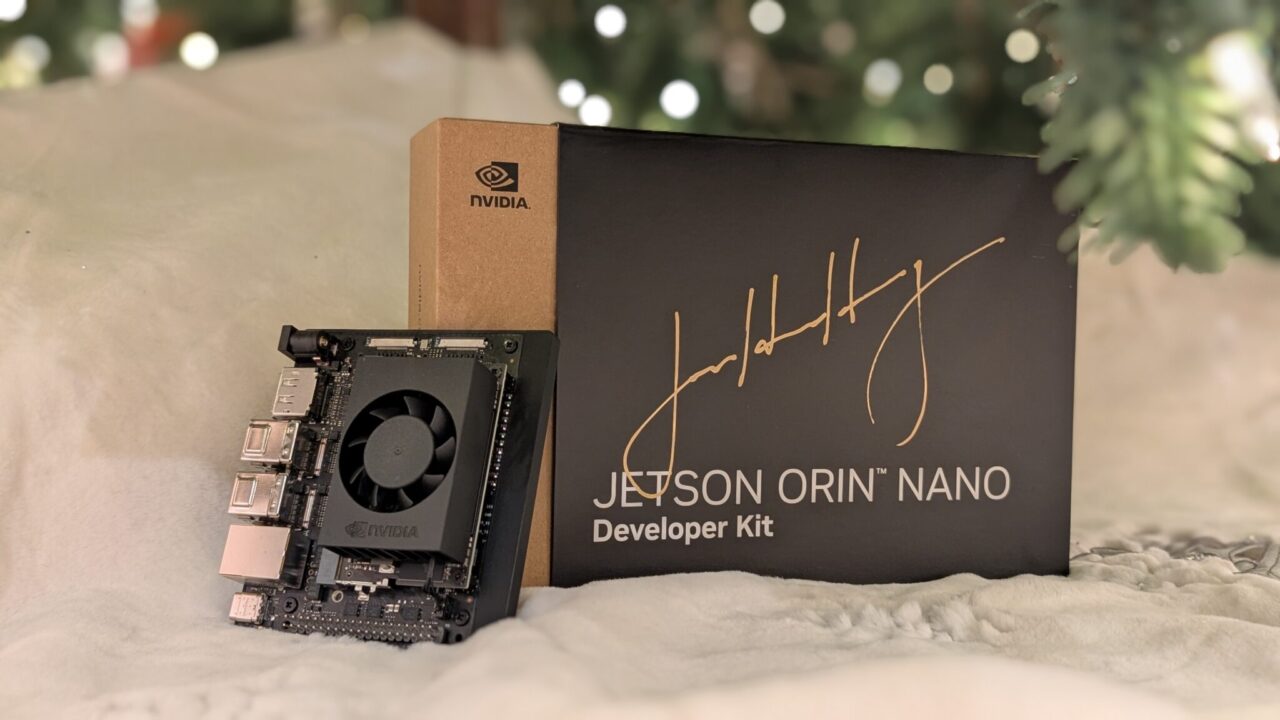
What NVIDIA's December 17, 2024 announcement meant for a first robotics AI project: the existing-kit upgrade, 8 GB memory constraints, full setup costs and useful acceptance tests.