In brief
Compliance helps when a tool must accommodate shape variation or distribute contact over a delicate product. It can also allow the product to move relative to the wrist and complicate release or cleaning. Evaluate the complete pickup-to-placement sequence using accepted product variation and explicit damage criteria before selecting a soft gripper.
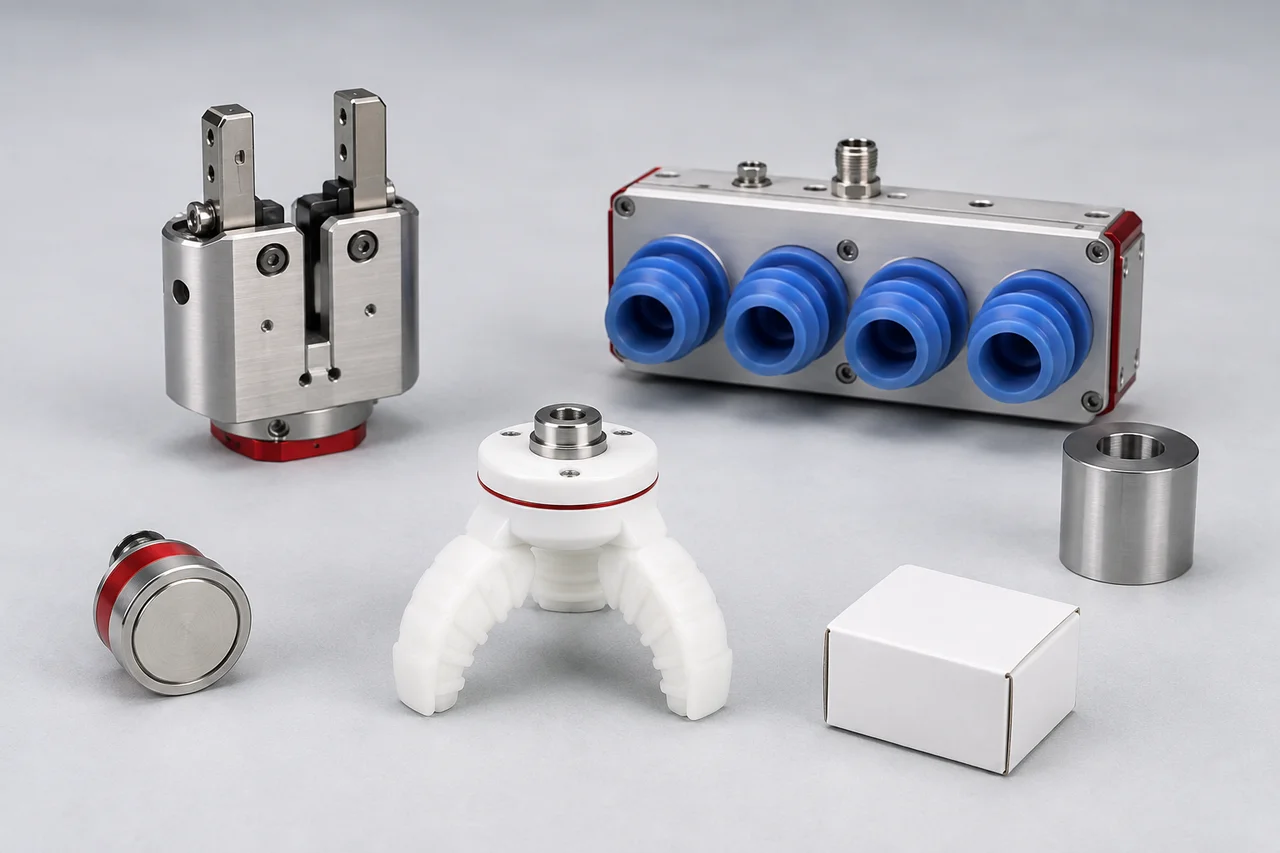
Identify what is soft and what actually moves
Soft gripper is a broad label. A conventional mechanism may carry flexible fingers, while another design wraps an elastic membrane around the object. The contact element, supporting structure and actuation can behave very differently. Request a drawing or demonstration explaining where deformation occurs and how the product is constrained. A compliant contact does not imply that the surrounding mount, robot or workpiece has no hazardous edges.
Festo's DHEF catalogue, edition 2025/01, describes an inverting-cap arrangement. Schmalz's mGrip announcement describes configurable pneumatic finger modules. They illustrate two architectures rather than interchangeable products. Choose the relevant mechanism by the available contact space and destination requirements. Avoid applying the performance or cleaning description of one design to an entire category simply because both use flexible material.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01 · Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024
Turn delicate handling into an inspectable requirement
Define damage with the people who accept the finished product. Immediate cracks and tears are only part of the problem. Cosmetic imprints, stretched seals, displaced contents or permanent changes in shape may matter after the next operation. Record where contact is permitted and whether temporary deformation is acceptable. Use reference samples and a repeatable inspection method so different observers can reach the same decision.
Separate product condition from handling success. A part can arrive in the nest and still fail quality inspection. For deformable products, specify when inspection occurs after release, because immediate appearance may differ from the later accepted state. This is a proposed evaluation method, not a claim that a particular product requires a fixed waiting period. Agree the relevant timing and observations with the product specialist.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01 · Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024
Check whether compliance preserves a useful pose
A robot's wrist position does not fully describe a product held in deformable contact. The product may settle differently as the fingers wrap or as its orientation changes. That may be acceptable when depositing into a spacious tray, but difficult when aligning a small feature with a close-fitting nest. Evaluate the product relative to the destination, rather than quoting robot repeatability as the complete placement result.
Ask whether the receiving fixture can locate the product after a tolerant transfer. A supported handoff or an additional locating step might be more practical than forcing the gripper to establish every datum. Include the space and sequence needed for that handoff in the trial. Compliance is beneficial when it absorbs unwanted variation while leaving the process-relevant features controlled; it is a liability when it hides their uncertainty.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01
Build a trial around different failure mechanisms
Select samples by the features that change contact: shape, stiffness, surface condition and permitted presentation error. Include several production lots when variation between lots is part of the concern. Do not repeatedly squeeze one demonstration sample and treat it as representative of fresh product. Retain sample identity, contact configuration and outcome so a damaged specimen is not unknowingly reused as a normal input.
The following matrix separates useful observations. Set the pass criteria with the relevant quality and integration specialists before the trial. Use competent personnel for physical work and keep hazards controlled. A simulation can organise these cases, but an uncalibrated soft-contact model cannot establish the actual product's deformation, marking or release behaviour.
| Variation | Observe | Decision it informs |
|---|---|---|
| Smallest accepted contour | Contact coverage and retained orientation | Finger or cap geometry |
| Most deformable accepted product | Shape after release and next operation | Contact setting and support |
| Permitted surface residue | Acquisition, slipping and adhesion | Material compatibility and cleaning |
| Different incoming orientation | Grasp consistency and placement | Presentation or fixture changes |
| Used contact element | Damage, release and visible deterioration | Inspection and replacement criteria |
References: Adaptive shape gripper DHEF, catalogue edition 2025/01 · Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024 · Maintenance of work equipment
Give release its own acceptance test
An enveloping grip must let the object leave at the intended time and location. Check whether contact sticks, catches an edge or changes the final orientation as the tool withdraws. A part that follows the gripper briefly can create a different placement than the robot programme appears to command. Record the product's final resting state after the empty tool has cleared the receiving area.
The DHEF catalogue explicitly describes a release sequence and a response when the object does not release. That is evidence that release needs deliberate consideration even in a compliant design, not a generic procedure for other soft tools. Have the supplier specify the supported sequence for the proposed hardware, then validate it with the actual part and destination under the integration team's controlled procedure.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01
Assess the complete cleaning arrangement
Ask for the exact contact-material identity and the supplier's cleaning instructions for the assembled tool. Include crevices, mounts, fasteners and utility connections in the review. The relevant product or hygiene specialist should assess compatibility with the intended cleaning agents, temperatures and process. A material description is not sufficient evidence that an entire cell meets the requirements of food, medical or other controlled production.
Schmalz describes mGrip as suitable for specified cleaning approaches in its dated manufacturer announcement. Keep that claim attached to the named product and request the current supporting documentation for the quoted configuration. In a non-food workshop, contamination can still matter: residue transfer may affect printing, bonding or cosmetic acceptance. Test the post-cleaning contact behaviour as well as the visible cleanliness, because both belong to the operating process.
References: Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024
Worked hypothetical example: a flexible gasket
Consider a simulated project moving soft gaskets from open trays onto an inspection plate. The gasket's outline varies slightly, and rigid fingers proposed at two points risk distorting an inspection feature. A compliant finger concept could distribute contact over approved outer regions. Before choosing it, the team specifies the allowed final outline, prohibited contact with the sealing face and the destination's ability to support the gasket.
A hypothetical trial could show successful pickup but inconsistent release, with one edge remaining attached and folding over. Increasing grip strength would not address that outcome. The next investigation should examine contact material, geometry and the supported release arrangement with the supplier. An alternative carrier or changed tray may prove more useful than a softer tool. None of these outcomes is asserted as a test result for DHEF, mGrip or any physical gasket.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01 · Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024
Make replacement restore the accepted contact behaviour
Flexible contact elements can be service parts whose condition affects the grip. Ask the manufacturer and maintainer to define relevant inspection signs and replacement criteria for the application. Record part identity, installation method and the checks needed after replacement. Do not substitute a visually similar material without reviewing its contact and cleaning behaviour. HSE guidance supports planned maintenance by competent people and suitable control of equipment hazards.
Use the acceptance record to connect service work to product quality. Preserve representative part conditions, the approved contact configuration and the release observations that justified selection. The record should state what was not demonstrated, such as a different cleaning regime or a later supplier's material. That allows a maintenance or product change to trigger a focused reassessment, without inventing a universal lifetime for soft fingers or a membrane.
References: Maintenance of work equipment · Adaptive shape gripper DHEF, catalogue edition 2025/01
Checklist
- Identify the deforming element and the way it constrains the product.
- Define cosmetic, structural and functional damage with the product owner.
- Measure final product pose independently of wrist position.
- Include accepted contour, stiffness and surface variation in samples.
- Observe release through complete tool withdrawal.
- Verify cleaning compatibility for the exact assembled tool.
- Document replacement identity and the checks that restore accepted contact.
Common questions
Does a soft gripper make a robot safe to work beside?
The contact element alone cannot establish the safety of the application. The robot, tool structure, workpiece, possible dropped objects and surrounding process all remain relevant. Have competent integration personnel assess the completed arrangement and required protective measures.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01 · Maintenance of work equipment
Can soft fingers deliver precise placement?
They may support a precise process when the grasp is consistent or the destination establishes the final location. Verify the product's pose after release under representative variation. Do not substitute wrist repeatability for evidence about a deformable product held by compliant contact.
References: Adaptive shape gripper DHEF, catalogue edition 2025/01
How often should compliant contact parts be replaced?
Use the exact manufacturer's instructions and application-specific condition criteria. Product surfaces, cleaning and duty can affect the service plan. Record inspection findings and verify the installed replacement; this documentary guide does not establish a universal cycle count or interval.
References: Maintenance of work equipment · Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024
Sources & review
Documentary guidance checked on 6 September 2026, using Festo DHEF catalogue edition 2025/01 and a dated Schmalz mGrip manufacturer announcement. Product claims do not establish application suitability or hygiene compliance. The gasket example is hypothetical; no hands-on testing is reported.
Audience: Light-assembly and product-handling teams evaluating compliant tooling. Updated .
- Adaptive shape gripper DHEF, catalogue edition 2025/01
- Finger gripper mGrip: flexible, hygienic, process-safe, 1 November 2024
- Maintenance of work equipment