Applications
Cobot palletising: reach, carton weight and mixed loads
Plan mixed-carton palletising around verified carton identity, complete tool load, reachable stack positions, stable patterns and recoverable pallet changes.
Task-specific questions for handling, inspection, packaging and workshop automation.
Plan mixed-carton palletising around verified carton identity, complete tool load, reachable stack positions, stable patterns and recoverable pallet changes.
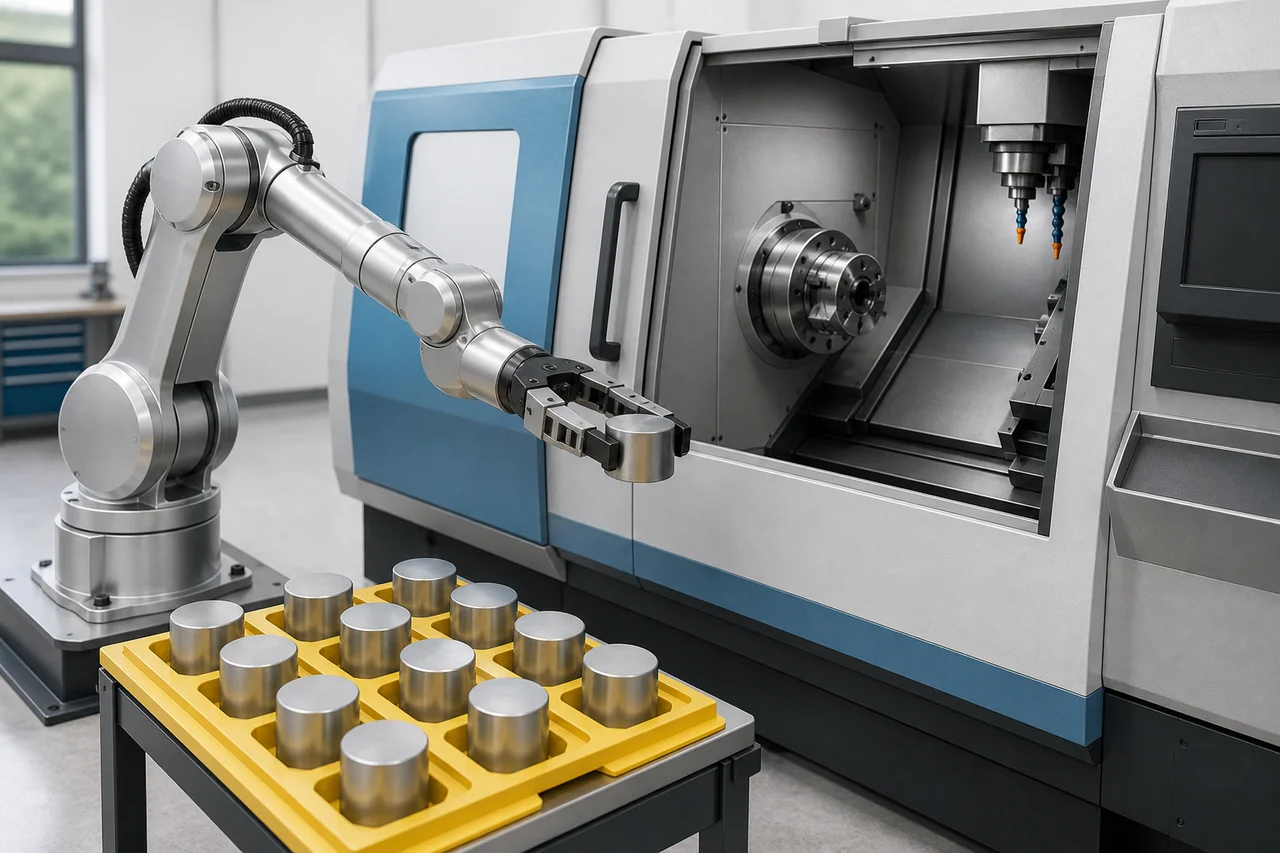
Scope CNC tending from blank presentation to accepted finished parts, including workholding, chips, machine handshakes, recovery and useful unattended time.
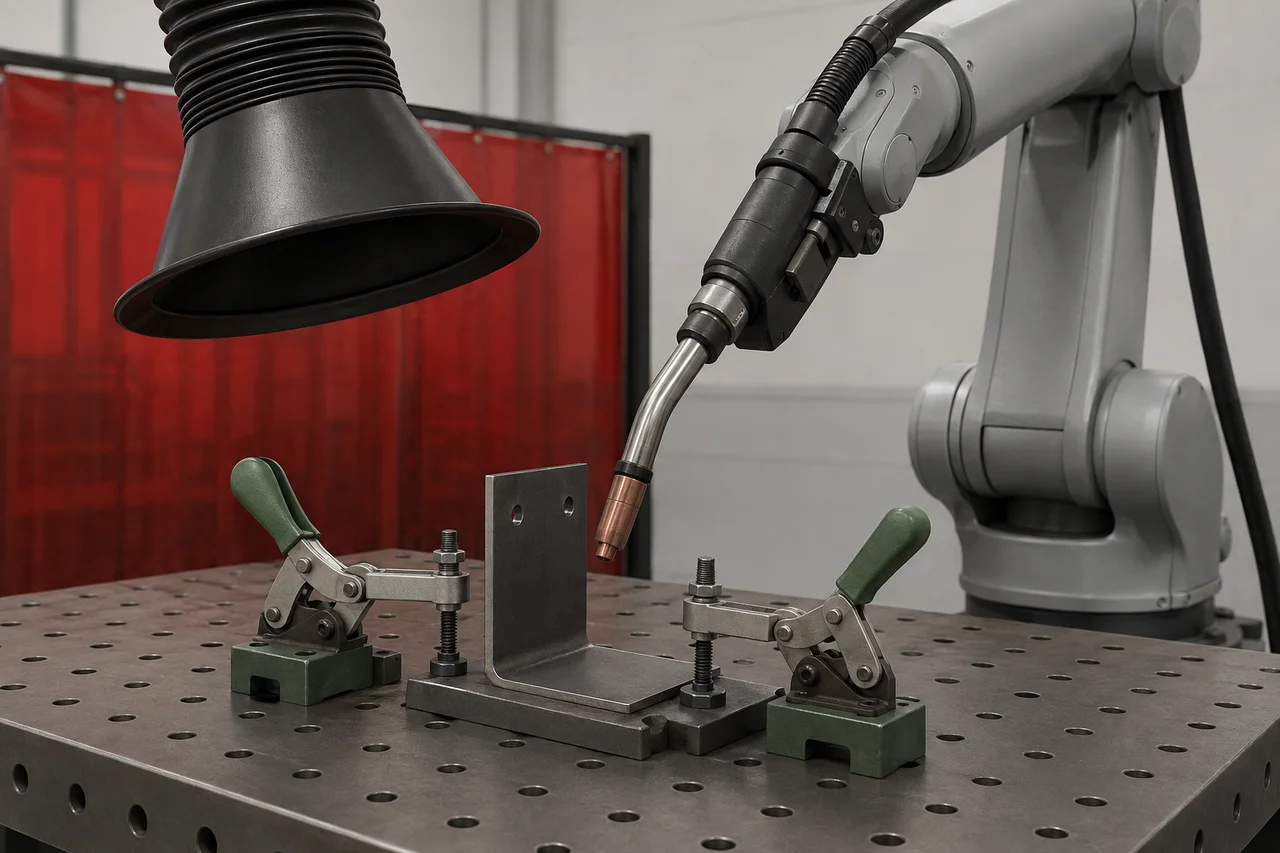
Plan a bracket-welding pilot around joint variation, fixture access, weld acceptance and complete batch time, with clear evidence for expanding or stopping.
Compare SCARA, delta, Cartesian and six-axis robots using the actual transfer, part presentation, gripping, usable throughput and complete installation scope.